
 Contacto
 Como comprar

Entrega
Guia de compras
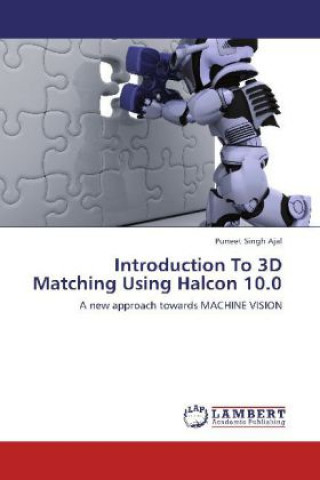
Introduction To 3D Matching Using Halcon 10.0
A new approach towards MACHINE VISION
 Inglês
 120 b
Até 30 dias para devoluções
Os clientes também compraram






 /
 Livro de capa dura
 114.30
€

 /
Capa mole
64.63
€



This work builds a system which can easily recognize the pose and determine the x , y and z coordinates of any object in real world with respect to camera position. Using Point Grey Bumble Bee 2 Stereo Vision System stereo images has been captured of the various objects. Estimating the 3D pose of an object is an important task in many application areas, e.g., during completeness checks or for 3D alignment in robot vision applications. For the 3D pose estimation with surface-based matching, a surface model is generated from a 3D object model that was obtained either from a 3D computer aided design (CAD) model or from a 3D reconstruction approach. A typical application area for 3D matching is robot vision, i.e., whenever robots are equipped with cameras that supply information about the parts to manufacture. Such systems are also called hand-eye systems because the robotic hand is guided by mechanical eyes . In order to use the information extracted by the camera, it must be transformed into the coordinate system of the robot.


Sobre o livro
Inglês

Ofereça este livro hoje
É fácil
1 Adicione ao carrinho e escolha Entregar como presente ao finalizar a compra 2 Receberá um vale 3 O livro chegará ao endereço do destinatárioTambém pode estar interessado em


 /
Livro de capa dura
30.35
€
 /
Capa mole
13.26
€
 /
Livro de capa dura
118.22
€
 /
Livro de capa dura
37.09
€
 /
Livro de capa dura
69.16
€
 /
Capa mole
7.73
€
 /
 Adobe ePub DRM
55.41
€



Olá! Sou o Libroamiko, o seu conselheiro de livros.
Como posso ajudar?