
Faça parte de uma comunidade de amantes de livros de todo o mundo e tenha acesso a uma série de benefícios.
Crie uma conta gratuitamente
Correio DHL 8.49 €
Correio DPD 4.99 €
Ponto DPD 4.49 €
Correio GLS 5.99 €
Correio MRW 5.99 €
Ponto GLS 4.99 €
 Contacto
 Como comprar

Ajuda
Entrega
Correio DHL 8.49 €
Correio DPD 4.99 €
Ponto DPD 4.49 €
Correio GLS 5.99 €
Correio MRW 5.99 €
Ponto GLS 4.99 €
Guia de compras
A minha conta
▸
Vazio :-(
0
Compact Environment Modelling from Unconstrained Camera Platforms
Dissertationsschrift
Língua
 Inglês
Livro
Capa mole
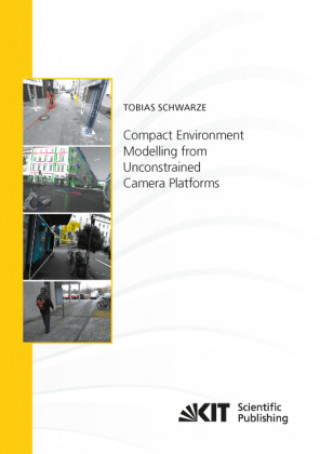
Mobile robotic systems need to perceive their surroundings in order to act independently. In this wo...
Descrição completa
Código Libristo: 20306945
?
 94 b
94 b
38.28
€
Armazenamento externo
Envio em 8-11 dias
Até 30 dias para devoluções
Os clientes também compraram
 /
 Capa mole
 60.48
€


 /
Livro de capa dura
15.69
€


 /
Capa mole
39.38
€
 /
Capa mole
33.08
€

 /
Livro de capa dura
15.89
€
 /
Capa mole
26.58
€

 /
Capa mole
37.28
€

Mobile robotic systems need to perceive their surroundings in order to act independently. In this work a perception framework is developed which interprets the data of a binocular camera in order to transform it into a compact, expressive model of the environment. This model enables a mobile system to move in a targeted way and interact with its surroundings. It is shown how the developed methods also provide a solid basis for technical assistive aids for visually impaired people.
Atriz
&
Poliglota
EWA KASP
para
Reproduzir vídeo


A Libristo tem a maior seleção de literatura estrangeira. É por isso que compro os meus livros aqui.
Sobre o livro
Nome completo
Compact Environment Modelling from Unconstrained Camera Platforms
Autor
Tobias Schwarze
Língua
Inglês
Inglês
Encadernação
Livro - Capa mole
Data de emissão
2018
Número de páginas
158
EAN
9783731508014
Código Libristo
20306945
Editoras
KIT Scientific Publishing
Peso
300
Dimensões
148 x 210 x 9

Ofereça este livro hoje
É fácil
1 Adicione ao carrinho e escolha Entregar como presente ao finalizar a compra 2 Receberá um vale 3 O livro chegará ao endereço do destinatárioTambém pode estar interessado em



 /
Capa mole
19.59
€
 /
Capa mole
9.69
€



 /
Capa mole
48.28
€


 /
Livro de capa dura
28.98
€

Conselheiro de livros Libroamiko
Ao utilizar este chat, está a comunicar com inteligência artificial generativa. Ao utilizá-lo, concorda também com o processamento de dados pessoais.
Olá! Sou o Libroamiko, o seu conselheiro de livros.
Como posso ajudar?
Olá, sou o Libroamiko, posso ajudar?